Our Robot
“Tyler Jack”
Drone Launcher
We started with a rubber-band and servo design, then redesigned to a 3D-printed sliding cartridge launcher. The launcher has an adjustable angle, allowing for compact and safe storage during the rest of the match.
Frame Design
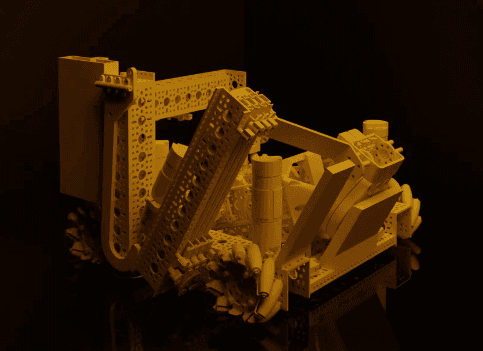
We started with a 17x17 inch frame standing 13.5 inches tall. Through iteration, we reduced the height to 12 inches and shortened the length for improved agility on the field.
Hanging System
Our powerless hanging system uses 2 linear actuators with upgraded higher RPM motors. The fold-out hooks use surgical tubing for 2.5x extension, allowing the robot to hoist itself and remain suspended without power.
Slide Control
We implemented a DPAD and button system replacing manual controls. Each press corresponds to one pixel layer, giving the driver precise control during the match.
Control Systems
5
Sensors
11
Servos
8
Motors
Odometry
Custom position tracking using dead-wheel encoders combined with an IMU for heading accuracy. Our odometry code is open-sourced on GitHub with accompanying YouTube tutorials.
Autonomous Movement
Our autonomous system adjusts minimum speed based on current battery voltage to prevent stalling. The Tele-OP mode features field-relative movement via IMU, turn-to-nearest cardinal direction, and variable DPAD pixel placement.